Robotics and Autonomous Systems
R2026bRobotics and autonomous systems describe systems of platforms, such as automobiles, airplanes, robots, and UAVs, that move and operate in a physical environment for goal-oriented actions. With the tools and algorithms in multiple toolboxes, you can simulate, estimate, navigate, and control the platform states, such as its position and velocity, as well as monitor the physical environment. Specifically, you can:
Design, model, and simulate autonomous system scenarios that include platforms, trajectories, paths, sensors, and environment using various coordinate systems and maps.
Generate and classify detections, estimate platforms, and obtain various maps of the environment.
Plan the paths of robots, UAVs, and automobiles using different path planning algorithms based on varied motion characteristics.
Control robots, UAVs, and automobiles using multiple motion control algorithms and strategies.
Connect to robots and simulators through middleware (e.g. ROS) and deploy your designed estimation, navigation, and control algorithms on hardware.
Products for Robotics and Autonomous Systems
Automated Driving Toolbox
Design, simulate, and test ADAS and autonomous driving systems
Robotics System Toolbox
Design, simulate, test, and deploy robotics applications
UAV Toolbox
Design, simulate, and deploy UAV applications
ROS Toolbox
Design, simulate, and deploy ROS-based applications
Sensor Fusion and Tracking Toolbox
Design, simulate, and test multisensor tracking and positioning systems
RoadRunner
Design 3D scenes for automated driving simulation
RoadRunner Scenario
Create and play back scenarios for automated driving simulation
Simulink 3D Animation
Simulate and visualize dynamic systems in a 3D environment
Topics
Offroad Autonomy
- Drive Agricultural Tractor in Vineyard Using Unreal Engine (Robotics System Toolbox)
Drive an agricultural tractor through a vineyard scene in Unreal Engine. (Since R2026b) - Generate Synthetic Sensor Data for Localization Using Unreal Engine (Robotics System Toolbox)
Simulate IMU and monocular camera data in Unreal Engine to develop and validate state estimation algorithms. (Since R2026b)
Scenario Design and Simulation
- Design a Curved Road Programmatically using MATLAB Scene Authoring Functions (RoadRunner)
Design a curved road using scene authoring functions. - Build RoadRunner Scene with Intersection and Static Objects Using RoadRunner HD Map (RoadRunner)
Build a RoadRunner scene containing a road intersection and surrounding static objects using a RoadRunner HD Map. - Create Driving Scenario Interactively and Generate Synthetic Sensor Data (Automated Driving Toolbox)
Use the Driving Scenario Designer app to create a driving scenario and generate sensor detections and point cloud data from the scenario. - Generate RoadRunner Scenario from Recorded Sensor Data (Automated Driving Toolbox)
Generate RoadRunner Scenario from recorded GPS data and preprocessed actor track list. - Aerodynamic Parameter Estimation Using Flight Log Data (UAV Toolbox)
Improve the accuracy of a UAV model by using flight log data to estimate the aerodynamic parameters of the UAV.
Situational Awareness and State Estimation
- Extended Object Tracking of Highway Vehicles with Radar and Camera (Sensor Fusion and Tracking Toolbox)
Track highway vehicles around an ego vehicle as extended objects that span multiple sensor resolution cells. - Resilient Pose Estimation Using Terrain-Aided Inertial Sensor Fusion in GPS-Denied Environments (Navigation Toolbox)
- IMU and GPS Fusion for Inertial Navigation (Navigation Toolbox)
This example shows how you might build an IMU + GPS fusion algorithm suitable for unmanned aerial vehicles (UAVs) or quadcopters. - Multi-Constellation GNSS Positioning Using RINEX Files (Navigation Toolbox)
Estimate GNSS receiver position using RINEX data from multiple satellite systems for improved accuracy and reliability. (Since R2026a)
Motion Planning and Control
- Object Tracking and Motion Planning Using Frenet Reference Path (Sensor Fusion and Tracking Toolbox)
Dynamically plan the motion of an autonomous vehicle based on estimates of the surrounding environment. - Plan Path for Manipulator in Simulink with Robotics System Toolbox (Robotics System Toolbox)
Simulate manipulator path planning in Simulink® with code generation for autonomy functions from MATLAB®. - Highway Lane Following with RoadRunner Scenario (Automated Driving Toolbox)
Simulate highway lane following application, designed in Simulink, with RoadRunner Scenario.
Hardware Deployment
- Run ArduPilot Software-in-the-Loop Simulation with Quadcopter Plant in Simulink (UAV Toolbox)
Verify a quadcopter controller design by using Software-in-the-Loop (SITL) simulation and simulating the quadcopter plant model in Simulink. - PX4 Hardware-in-the-Loop (HITL) Simulation with Fixed-Wing Plant in Simulink (UAV Toolbox)
This example shows how to use the UAV Toolbox Support Package for PX4® Autopilots to verify the controller design by deploying the design on the PX4 Autopilot hardware board. - Estimating Orientation Using Inertial Sensor Fusion and MPU-9250 (Navigation Toolbox)
This example shows how to get data from an InvenSense MPU-9250 IMU sensor, and to use the 6-axis and 9-axis fusion algorithms in the sensor data to compute orientation of the device. - Sign Following Robot with ROS in MATLAB (ROS Toolbox)
Control a simulated robot running on a separate ROS-based simulator over a ROS network using MATLAB.
ROS Data and Network Analysis
- Visualize Messages from Live ROS or ROS 2 Topics (ROS Toolbox)
Visualize messages from live ROS or ROS 2 topics in ROS Data Analyzer app. - Publish Ground Truth and Sensor Data from RoadRunner Scenario to ROS 2 Network (ROS Toolbox)
Publish ground-truth and sensor data from a RoadRunner scenario to ROS 2 network and visualize it using ROS Data Analyzer app. (Since R2025a)
Featured Examples
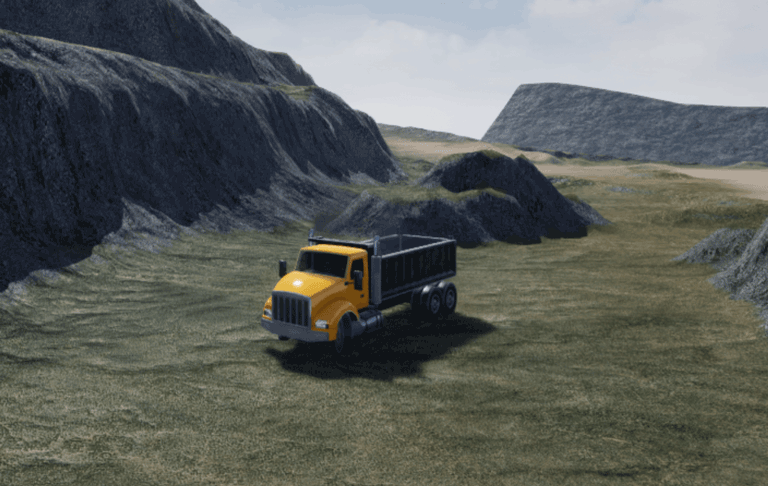
Offroad Navigation for Autonomous Haul Trucks in Open Pit Mine
Series shows how to create a set of planners to enable autonomous haul trucks to navigate uneven terrain and avoid obstacles.
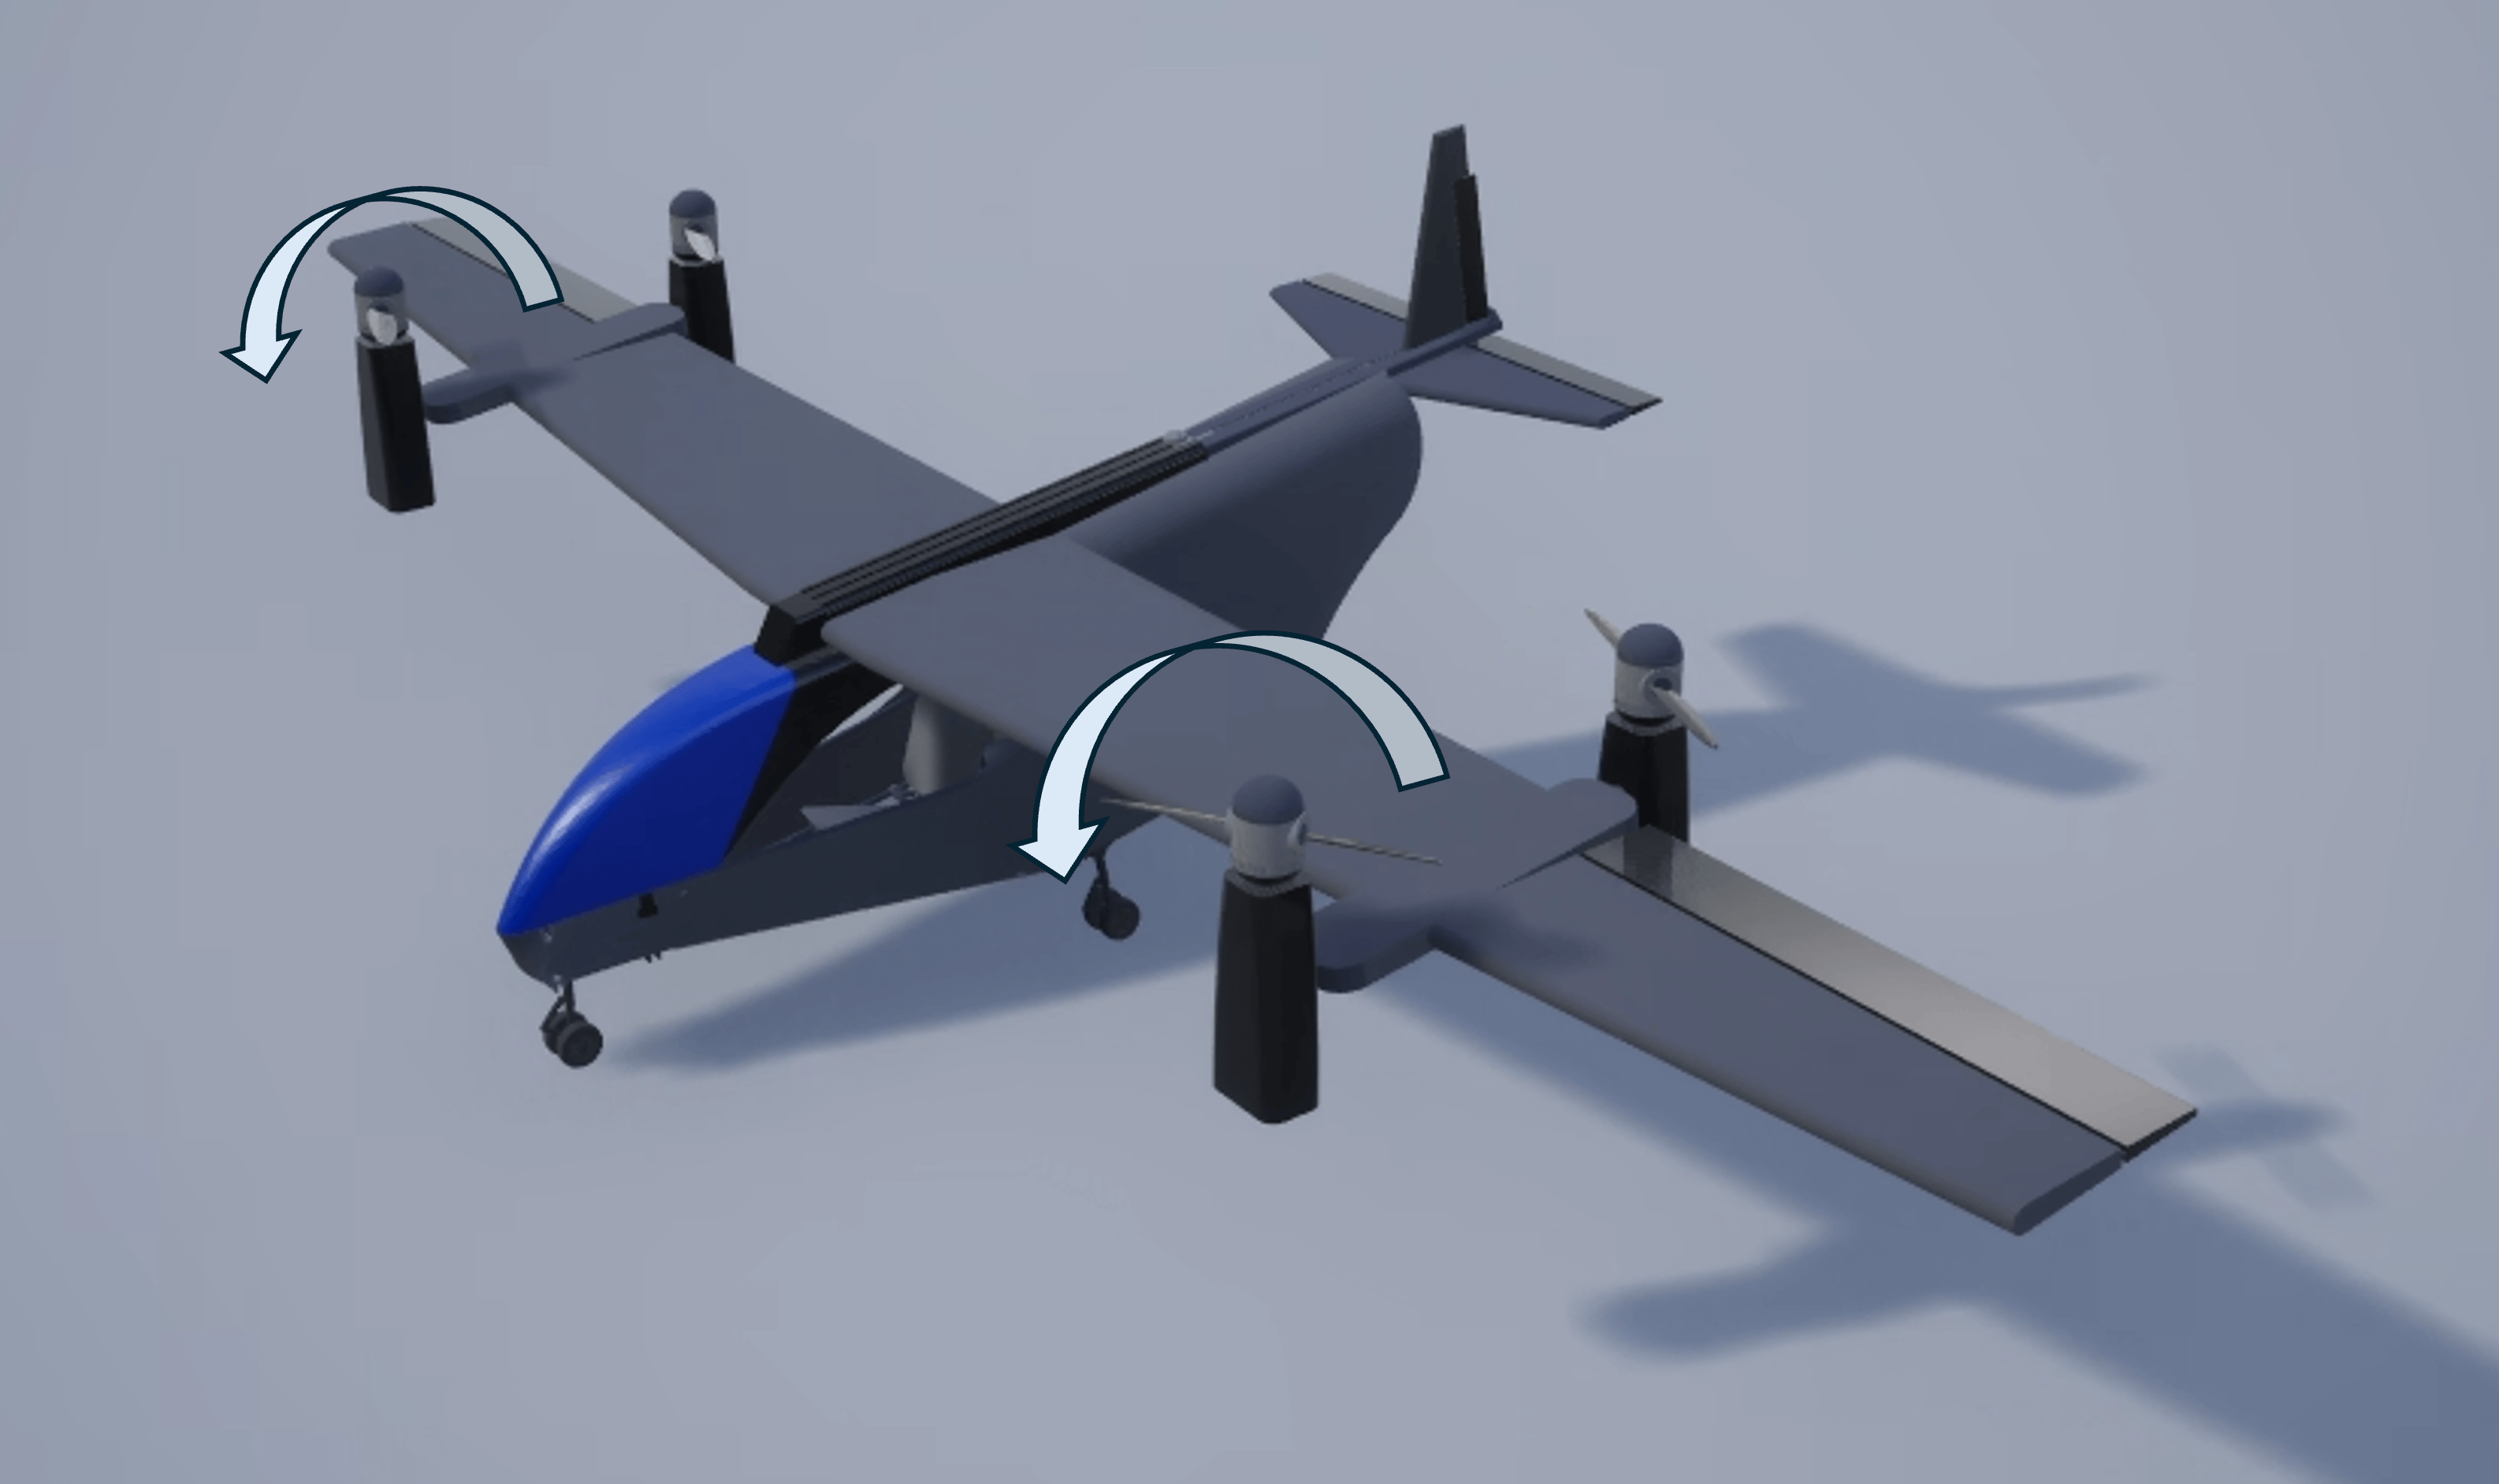
Design and Tune Controller for VTOL UAV
Design, tune, and deploy a flight controller for a tilt-rotor VTOL UAV in urban air mobility applications using Simulink.
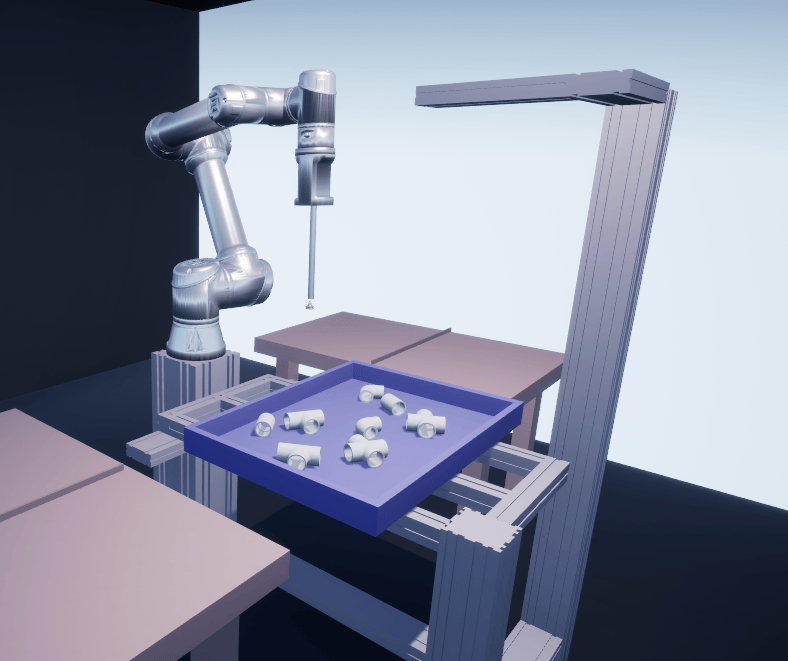
Intelligent Bin Picking System in Simulink
Design an intelligent bin picking system for a manipulator in an Unreal Engine simulation environment.
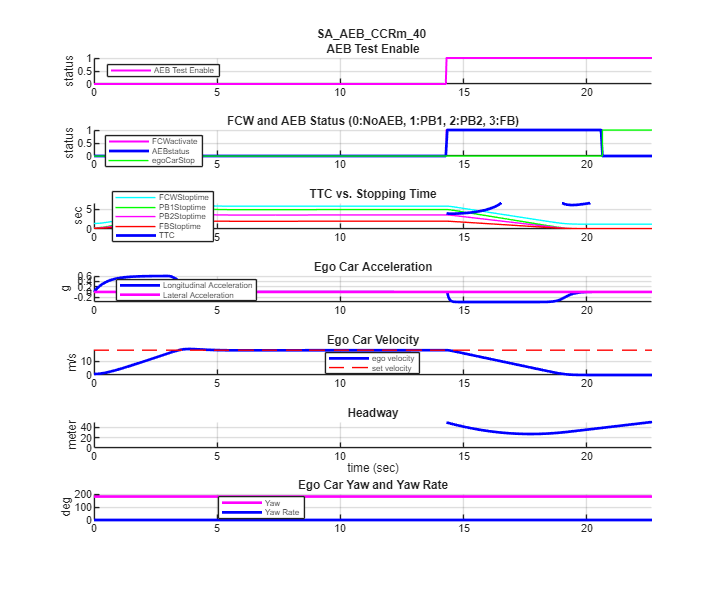
AEB Test Bench for Euro NCAP Scenarios
Configure AEB test bench designed in Simulink and simulate a scenario in RoadRunner Scenario per Euro NCAP® testing protocols.
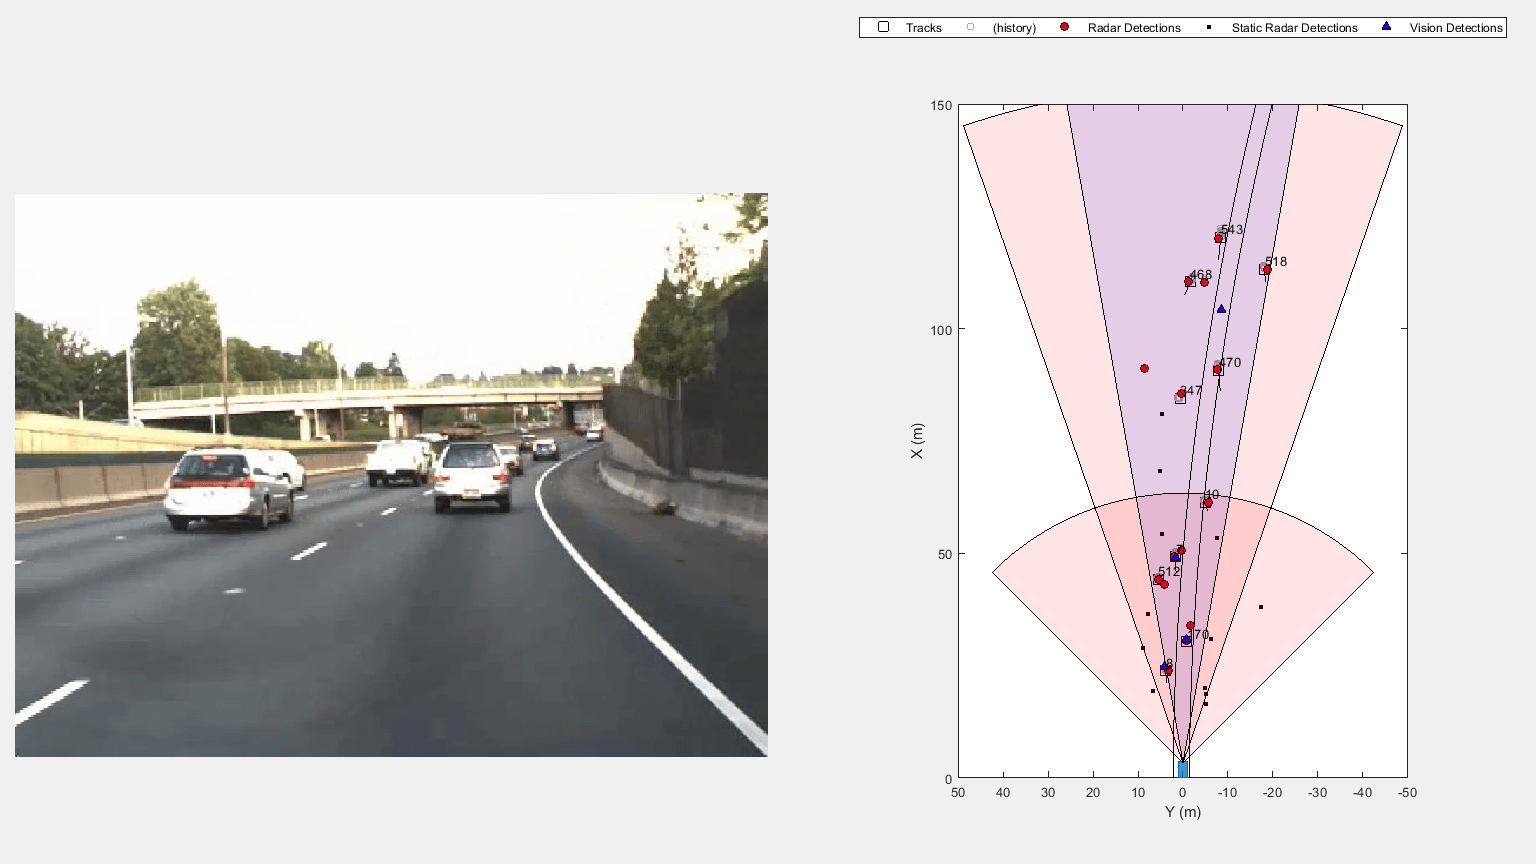
Processor-in-the-Loop Verification of JPDA Tracker for Automotive Applications
Generate embedded code for a JPDA tracker and verify it using processor-in-the-loop (PIL) simulations.
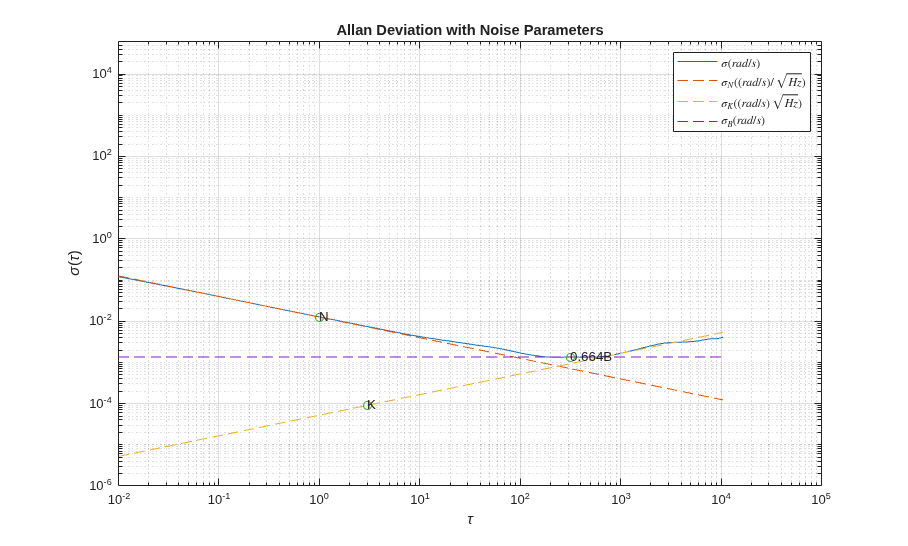
Inertial Sensor Noise Analysis Using Allan Variance
Use the Allan variance to determine noise parameters of a MEMS gyroscope. These parameters can be used to model the gyroscope in simulation. The gyroscope measurement is modeled as:
Videos
Developing Autonomous Systems with MATLAB and Simulink
This video shows how to develop workflows for modeling and simulation of
autonomous vehicles, designing autonomous algorithms, virtual testing of
the systems, and deploying to hardware.
Autonomous Technologies for Aerospace-Defense Applications
This video shows how to develop autonomous technologies for aerospace and
defense applications like Unmanned Aerial Vehicles (UAV), Unmanned Ground
Vehicles (UGV), and Autonomous Underwater Vehicles (AUV).
Design and Deploy Collaborative Robots (Cobots) Using MATLAB
This video shows how to use Robotic System Toolbox for designing,
simulating, testing, and deploying robotic applications including
cobots.
Shaping a Path to Offroad Autonomy Using MATLAB
This video explores how MATLAB and Simulink accelerate control and
automation design for offroad machinery through simulation, sensor fusion,
and HIL testing.
Design and Simulate VTOL Aircrafts for Advanced Air Mobility
Applications
This video shows how to develop VTOL control systems and photorealistic
simulations to simulate Advanced Air Mobility Missions.

